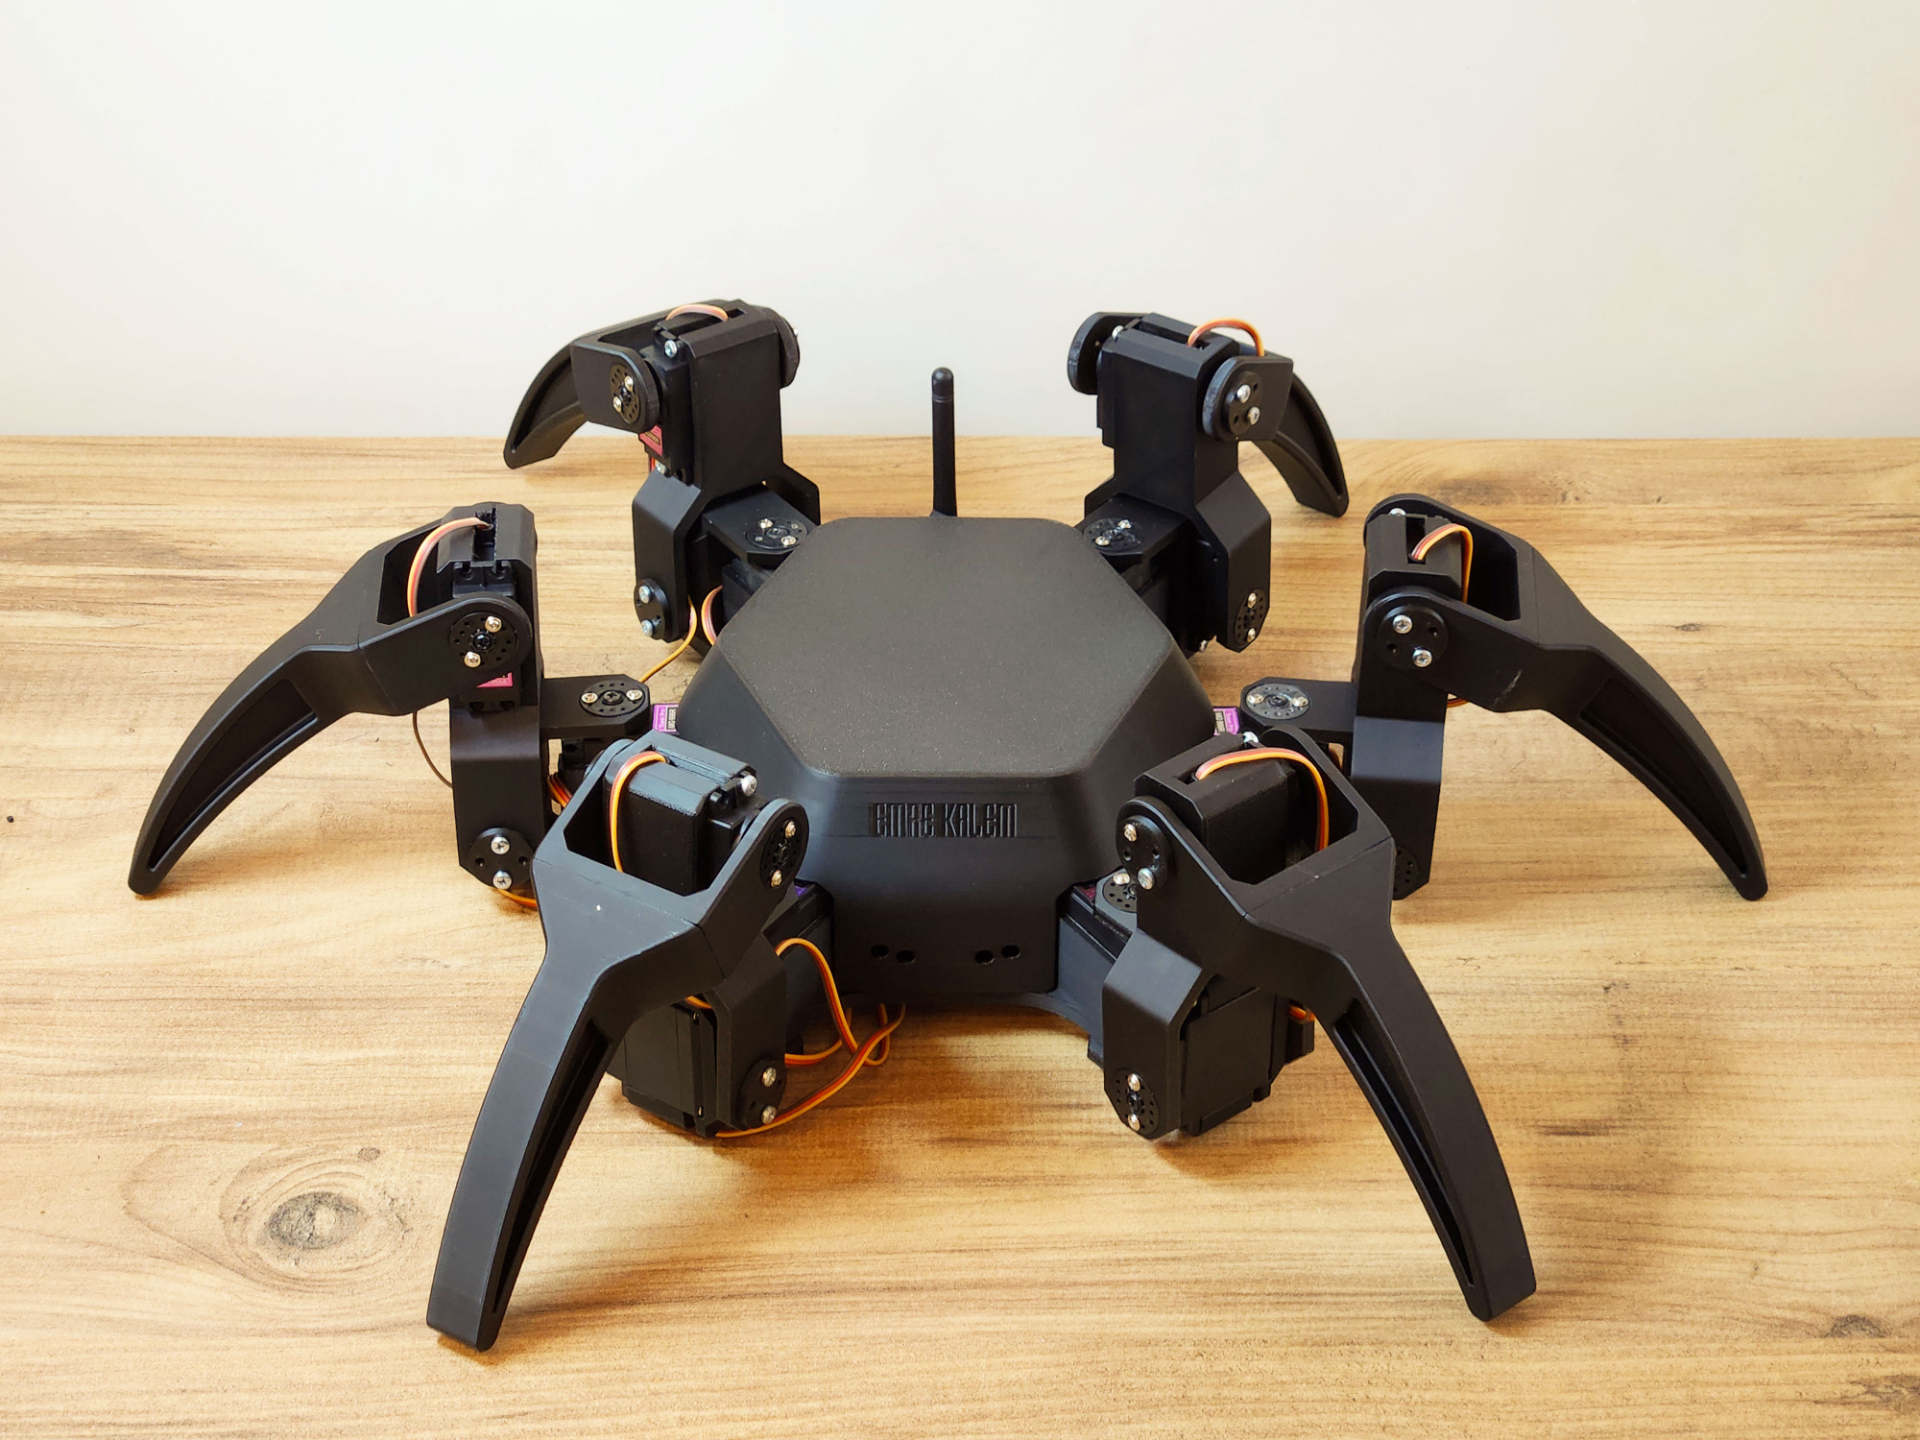
Assembly and Test Video: Arduino-Based 6-Legged Hexapod Spider Robot This project features a 6-legged (hexapod) walking robot controlled by an Arduino Mega. Each leg has 3 degrees of freedom (18 servo motors total), enabling smooth and balanced movement using a tripod gait algorithm. The robot is remotely controlled using an NRF24L01 wireless module. With dual joysticks and potentiometers on the controller, users can adjust the robot's direction, walking speed, and body height. This project is still under development. Software development work is ongoing. You can find all the necessary source code, Gerber files, and circuit schematics in the video description. Required Parts for Hexapod Robot: Arduino Mega x 1 XL4016 Voltage Regulator x 1 NRF24L01 PA + LNA x 1 NRF24L01 Power Adapter x 1 Li-Po Battery 3S 2200 mAh x 1 MG996R Servo (180 ° ) x 18 KCD1 Rocker Switch x 1 695 Bearing x 18 Jumper Cables (Servo Cable Extender) M3x6mm Bolts x 90 M3x10mm Bolts x 90 Required Parts for RC Controller: NRF24L01 PA + LNA x 1 NRF24L01 Power Adapter x 1 Arduino Uno x 1 Dual Battery Holder for 18650 Battery x 1 18650 Li-ion Battery x 2 Toggle Switch (5mm) x 3 10K Potentiometer x 2 Joystick Module x 2 Jumper Cables M3x6mm Bolts x 18 Links: Hexapod & Controller Code: https://drive.google.com/file/d/1bIMGIhBOq_qt7qGt7REMtUuWCw7WB5hj/view?usp=sharing Gerber Files for PCB: https://drive.google.com/file/d/10F6qPQ1kVP-xbSKdnUb0b_vhInIYOMQE/view?usp=sharing Hexapod Circuit Schematic: https://app.cirkitdesigner.com/project/f2cca481-7fbb-4e6d-9743-3ebf409ca84c PCB Order: https://jlcpcb.com/?from=emrekalem
Hexapod Spider Robot with Servo & Arduino
by Emre Kalem · original on MakerWorld ↗
♥ 5.4k⬇ 5.0k🖨 565 prints
Print profiles
0.2mm layer, 3 walls, 10% infill
⏱ 29h 27m · 1155 g · 1 material(s)
Prints on: P1S 0.4, H2C 0.4, H2D Pro 0.4, P1P 0.4, X1 0.4, A1 0.4, X1E 0.4, X1 Carbon 0.4, H2S 0.4, P2S 0.4, A2L 0.4, H2D 0.4, X2D 0.4PLA
Not printable on our printers